
Building mechanical systems, test hardware, and prototypes for aerospace, robotics, and engineering applications.
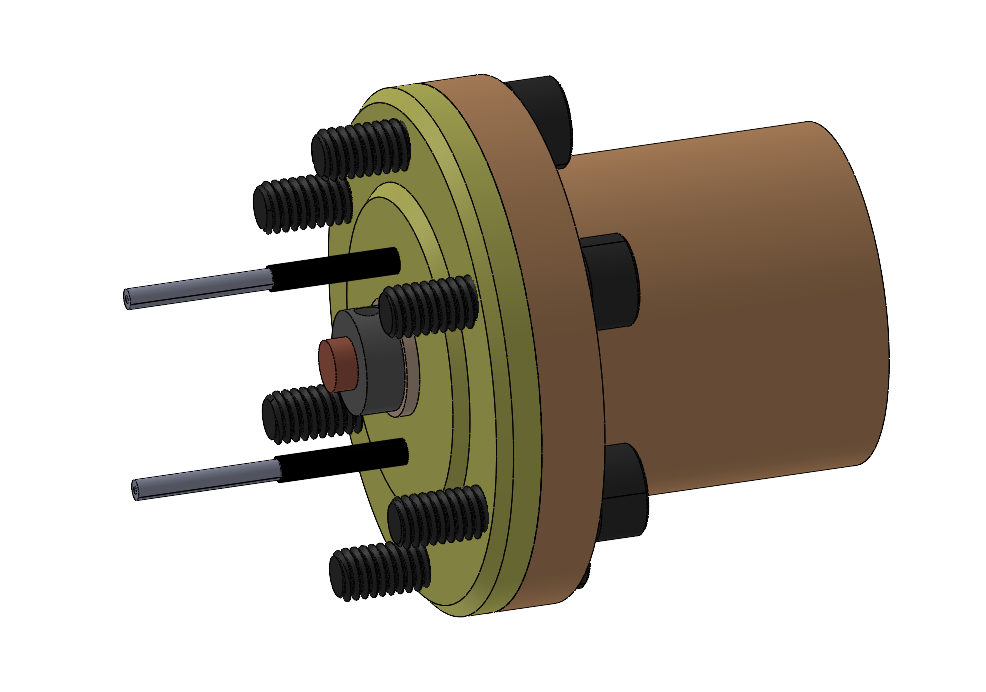
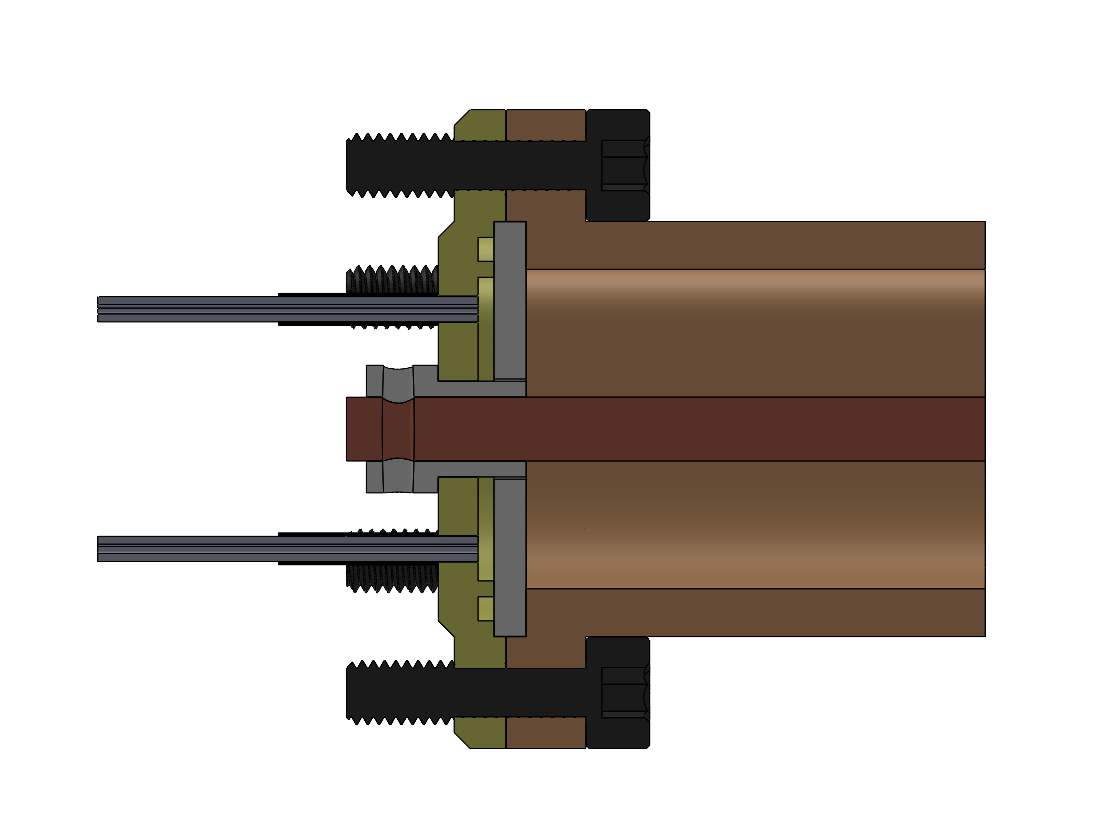
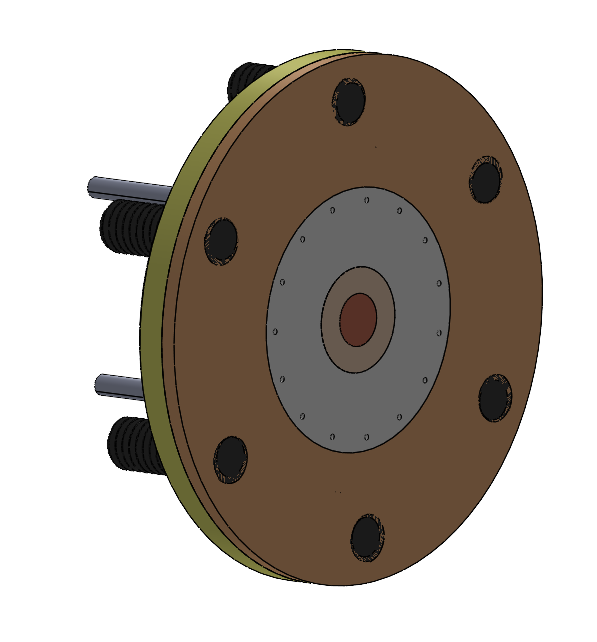
Objective: Lead a 13-member team developing UVA’s first electric thruster: a coaxial, argon-fed pulsed plasma thruster designed to investigate reliable self-ignition and electromagnetic plasma acceleration.
Methods: Designed the thruster, gas delivery, and 200–1500 V power-processing architecture while using reduced electric field (E/N) analysis and CFD to optimize breakdown conditions and gas distribution for a target 50–100 µg mass bit.
Current Work: Developing the integrated prototype and vacuum test setup to characterize electrical discharge behavior, impulse bit, and specific impulse.
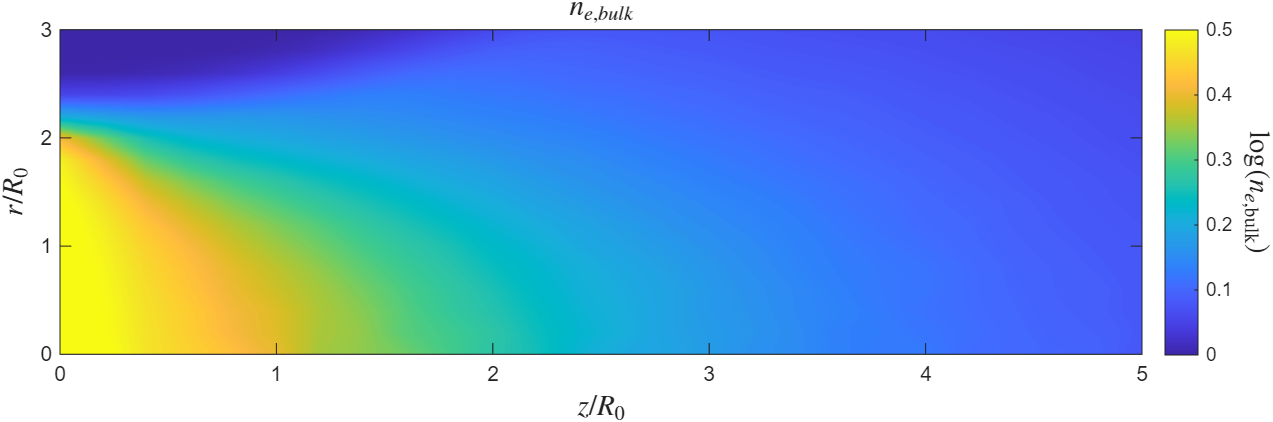
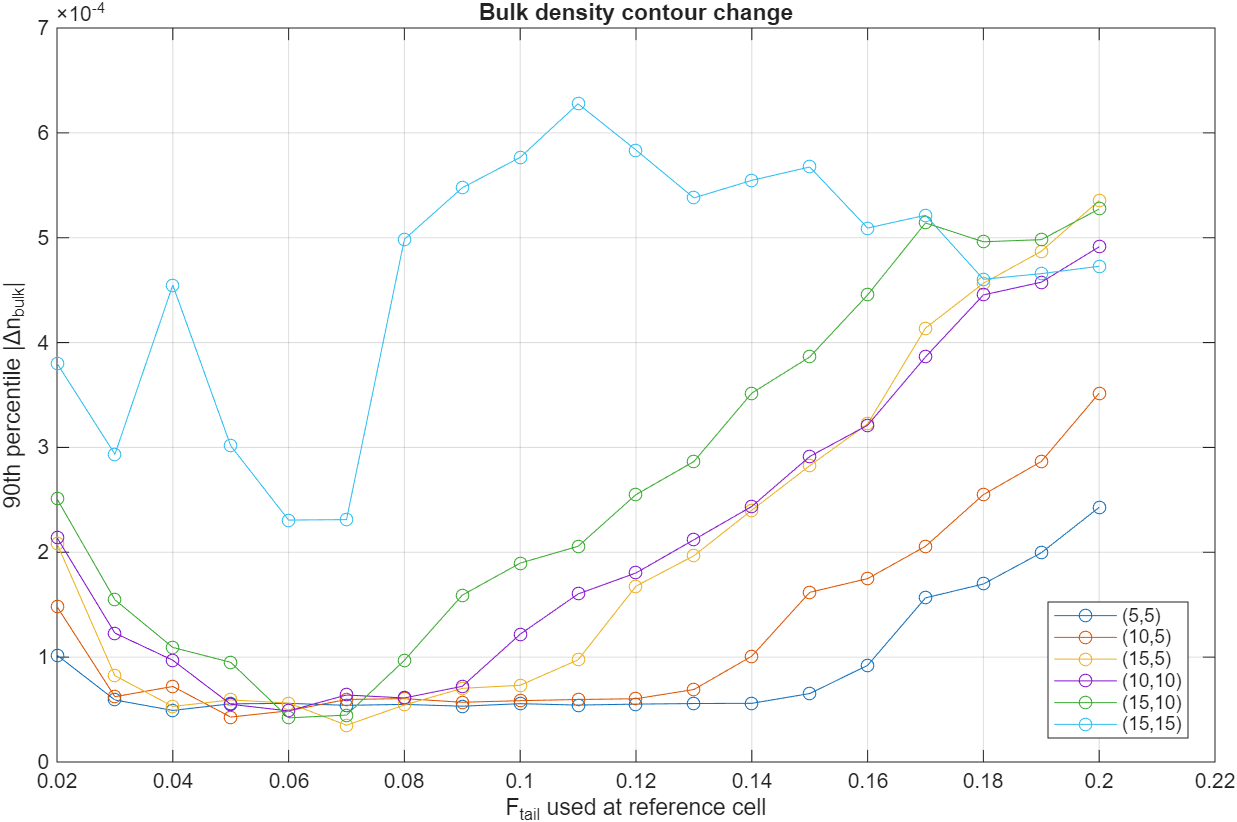
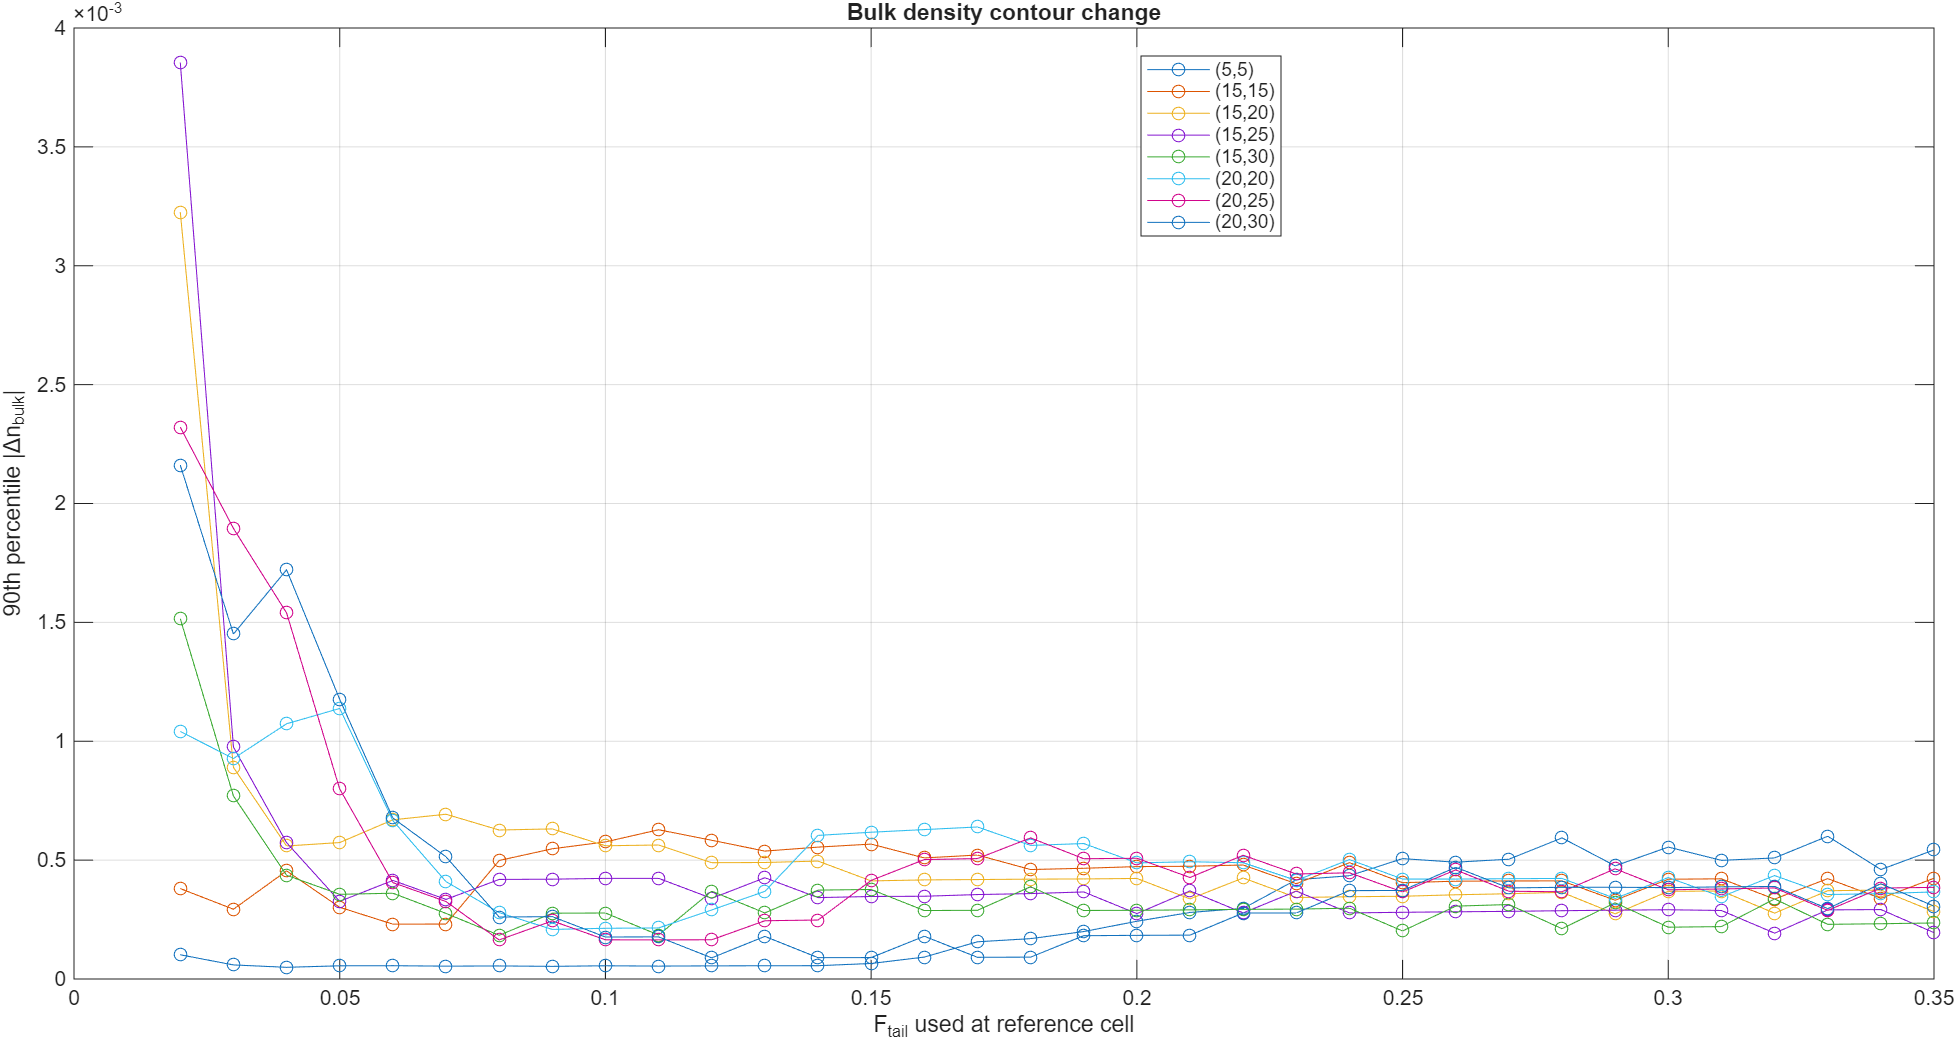
Objective: Investigate electron thermodynamics and current formation in magnetic nozzle plasma expansion using fully kinetic particle-in-cell (PIC) simulations.
Methods: Execute PIC simulations on HPC systems and post-process plasma data in MATLAB, analyzing electron temperature, density, and energy distributions to quantify the influence of high-energy tail electrons.
Results: Developed a contour-based sensitivity analysis that identified approximately the top 12% of electron energies as the threshold separating tail and bulk populations, supporting ongoing research into electron thermodynamics and azimuthal current formation.
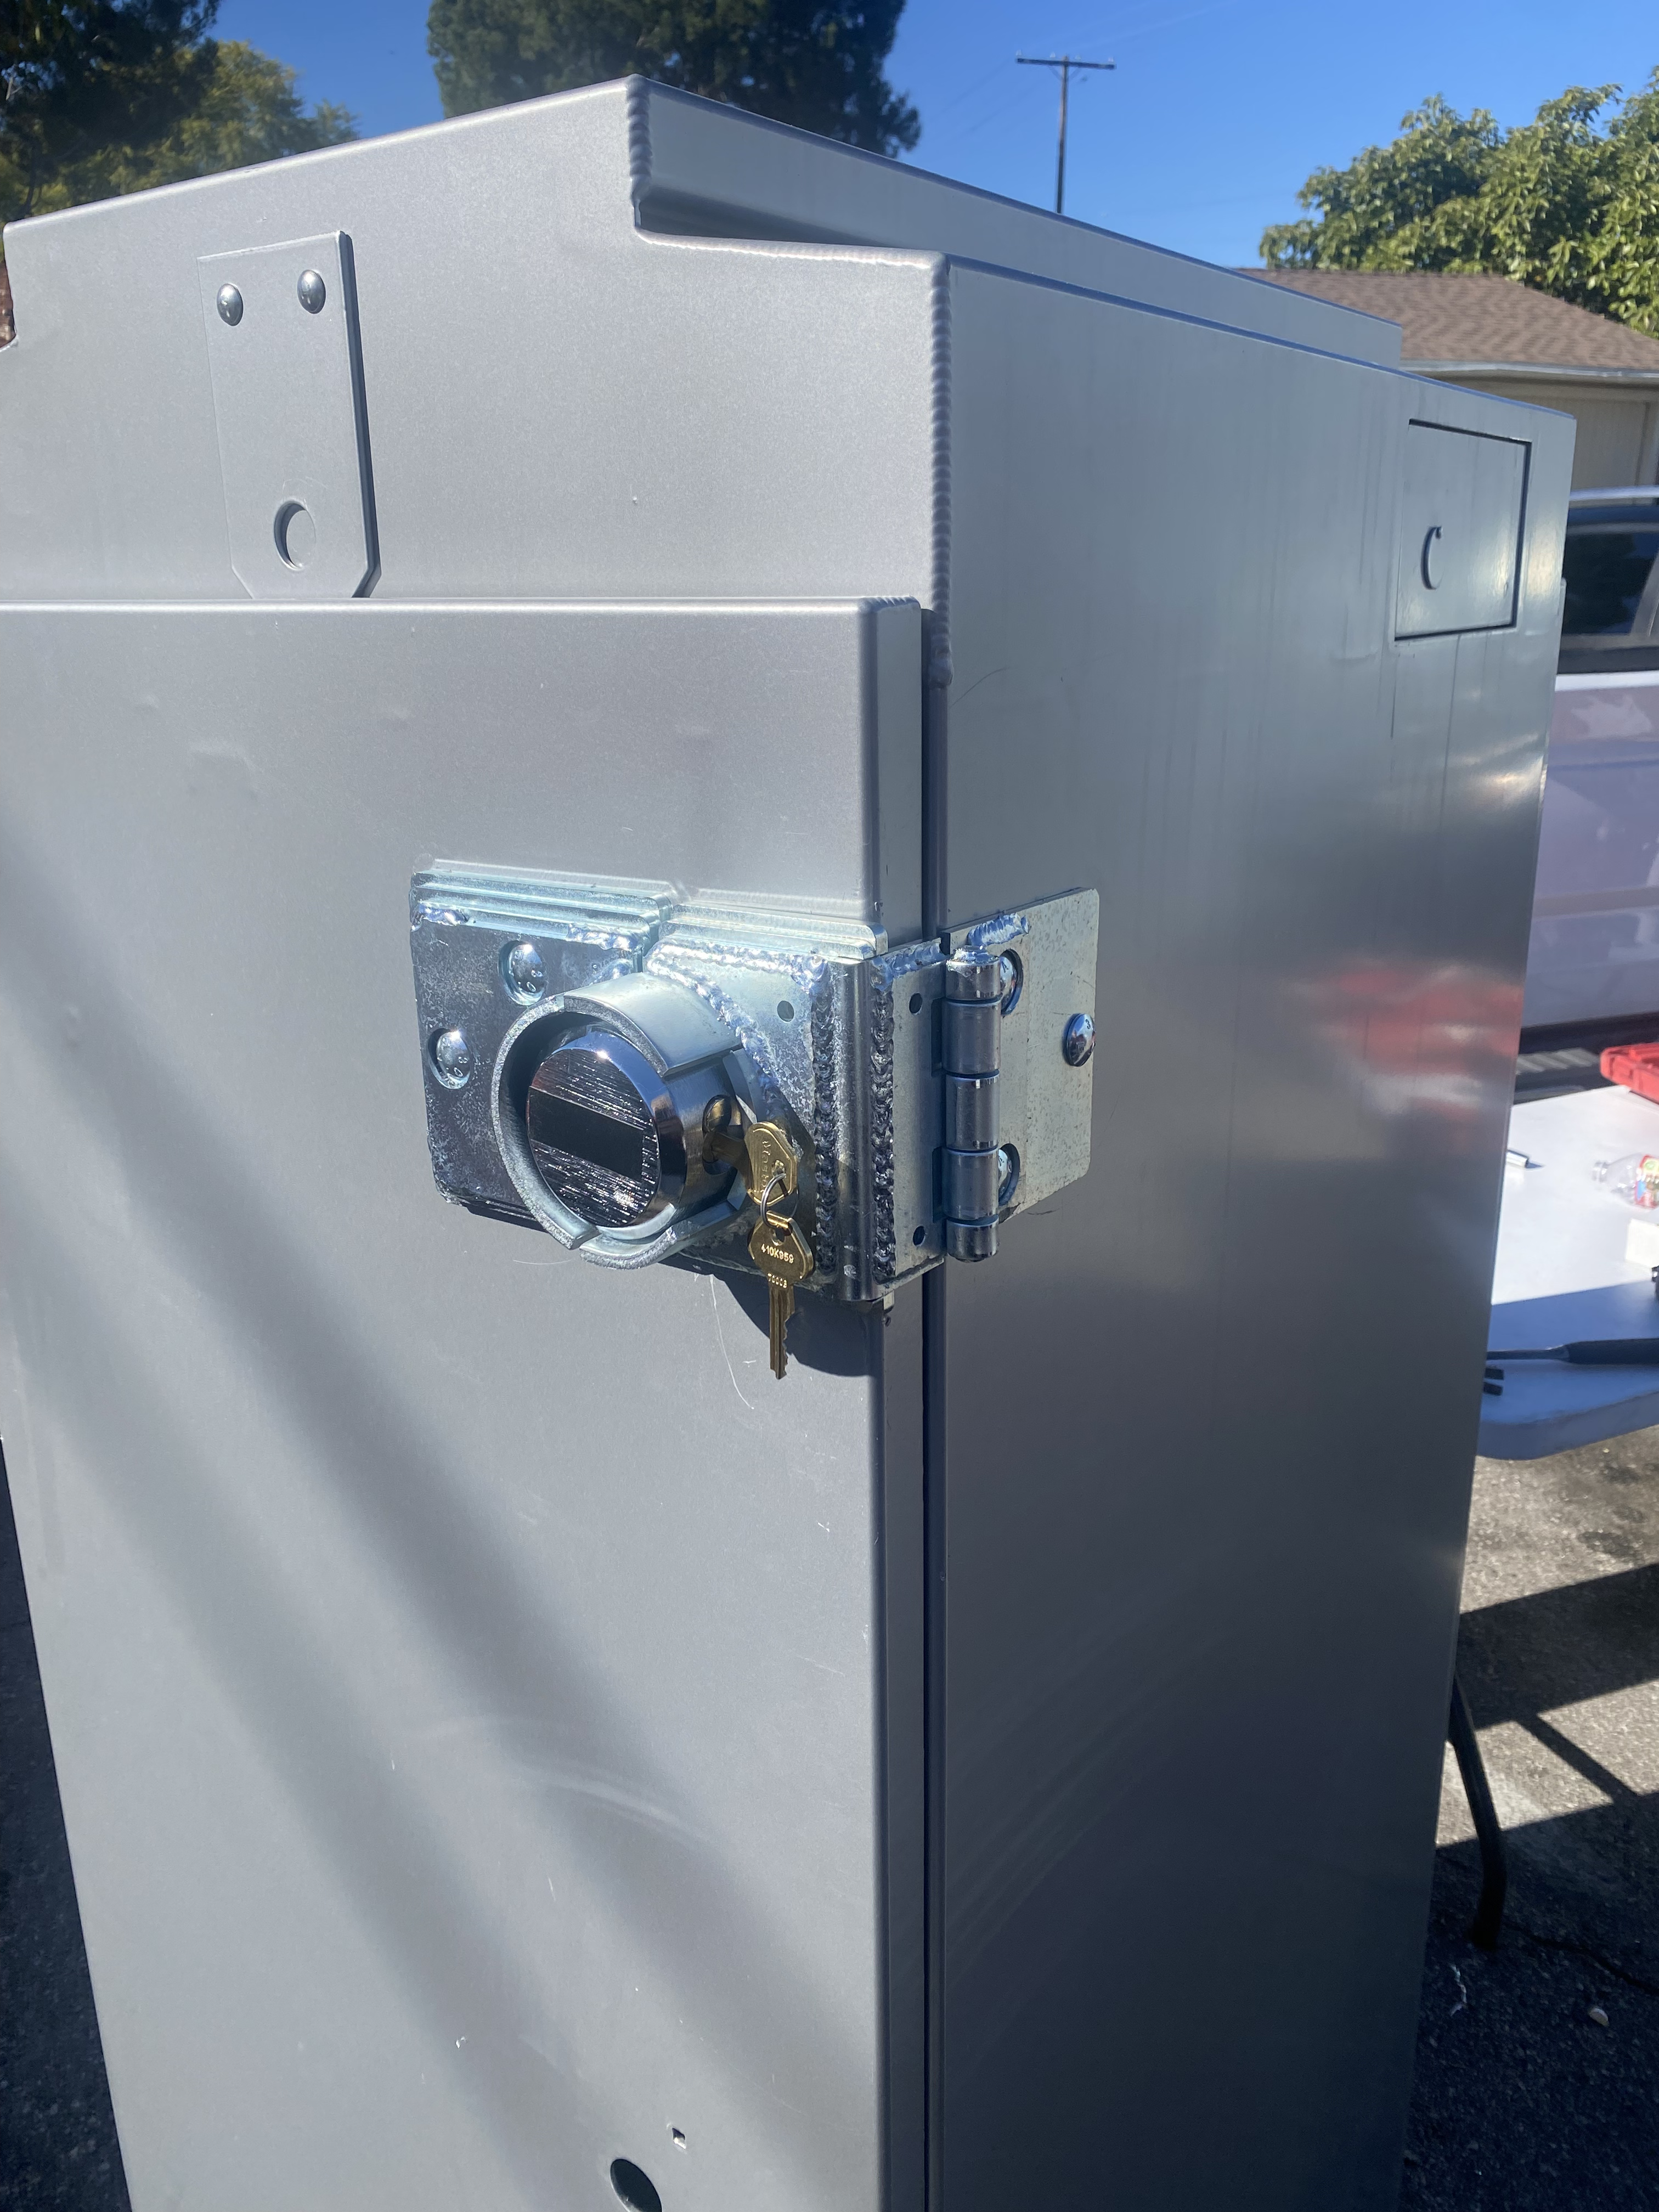
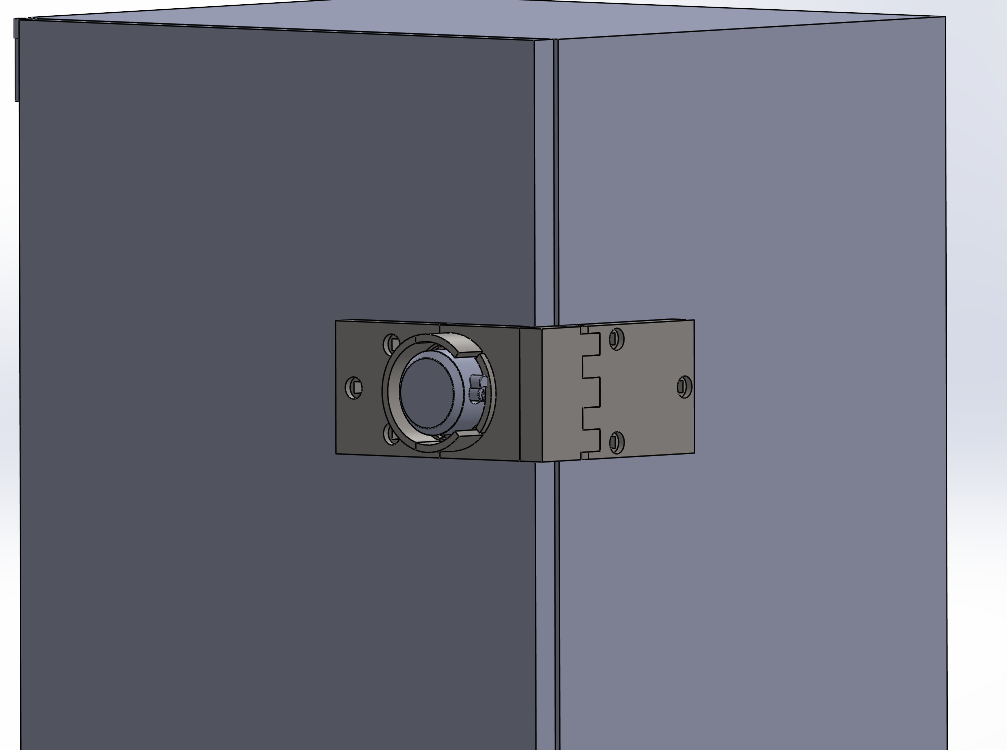
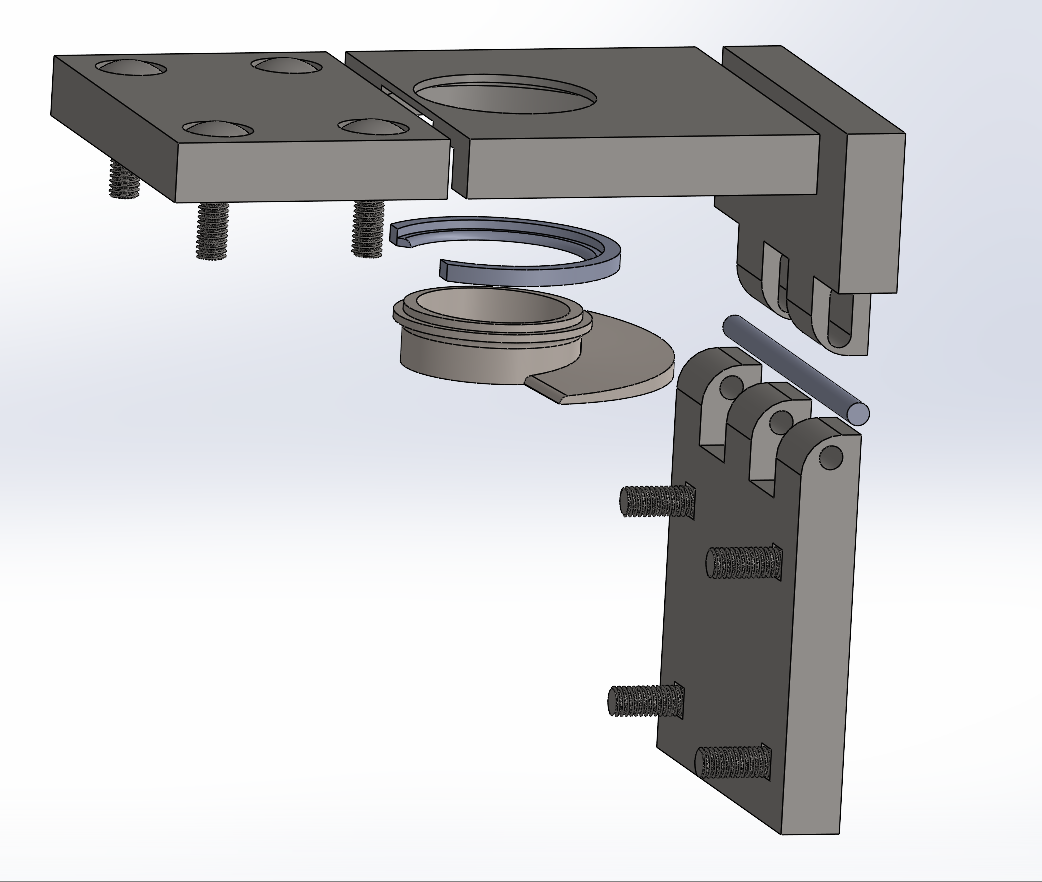
Objective: Improve theft deterrence and field deployment for municipal electrical boxes while simplifying the lock body for manufacturable production.
Method: Redesigned the mechanism into a simplified finger-joint body, validated joint engagement with SolidWorks motion and tolerance checks, and produced fabrication-ready drawings.
Results: Reduced part count from 15 to 7, improved locked assembly robustness, supported manufacturer geometry refinement, and achieved a 10% manufacturing cost reduction with a fabricated prototype.
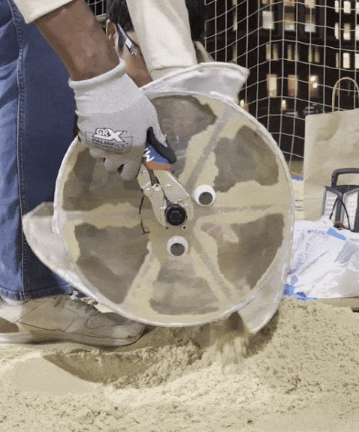
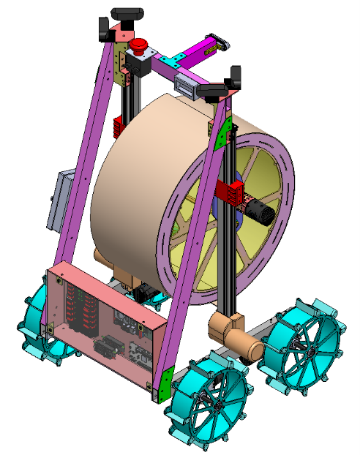
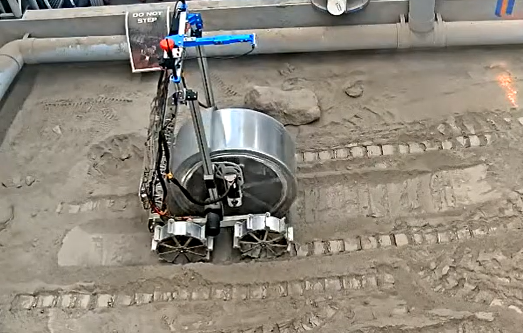
Objective: Design and manufacture a spinning bucket drum-based rover to excavate and build berms in a Lunabotics-style testbed.
Methods: Used SolidWorks for full CAD and FEA, then fabricated components via water jet, Prototrak mill, roller forming, and welding.
Results: Achieved 5th overall at NASA Lunabotics 2025 and earned the Innovation Award and the Granular Mechanics Award.
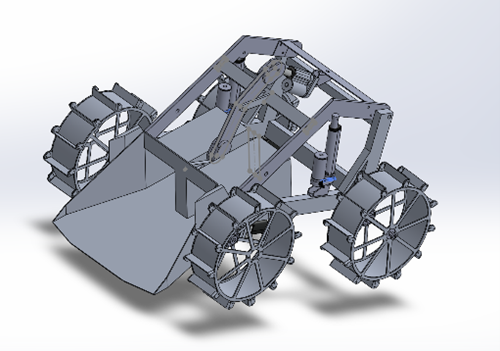
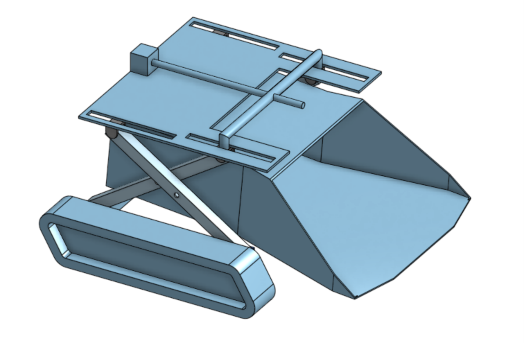
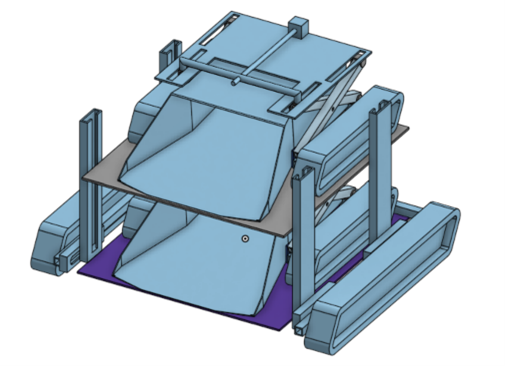
Objective: Design a front loader that maintains high digging capacity and rate while significantly reducing mass versus conventional designs.
Methods: Modeled designs in SolidWorks and Onshape; ran FEA on bucket structures to assess strength under digging and tipping loads.
Results: Shifted the center of mass between the wheels, enabling roughly a 20 kg mass reduction compared to typical front loader layouts.
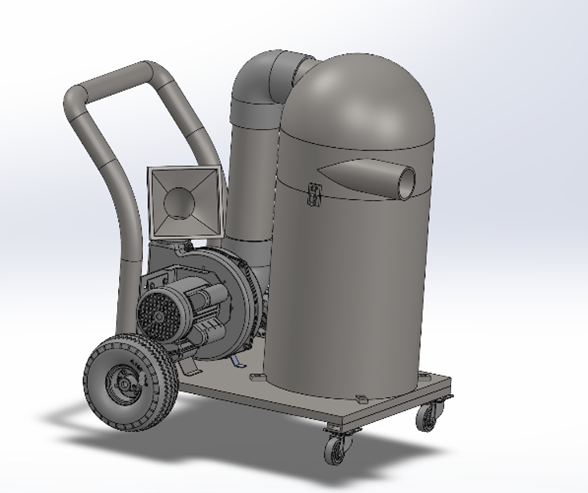
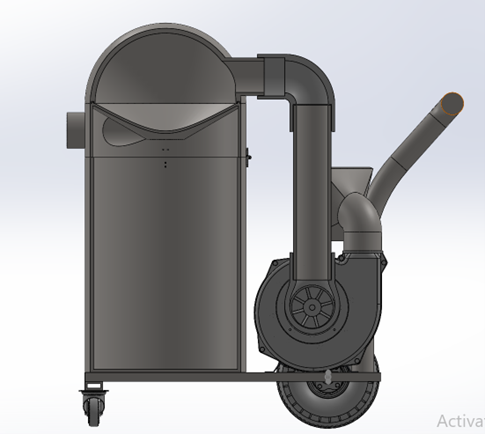
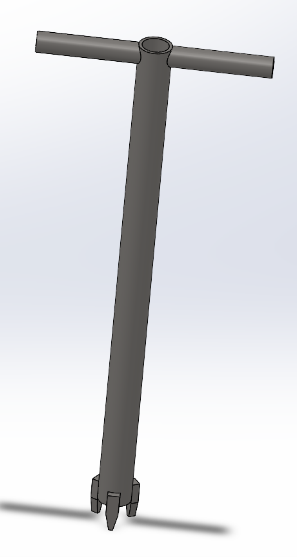
Objective: Create a vacuum-based excavation tool capable of efficiently removing soil and debris while separating and storing solids.
Methods: Modeled airflow paths in SolidWorks and integrated a cyclone separator feeding a modular dirt compartment.
Results: Demonstrated effective dirt removal driven purely by fluid suction and filtration, generating interest from companies such as Home Depot.
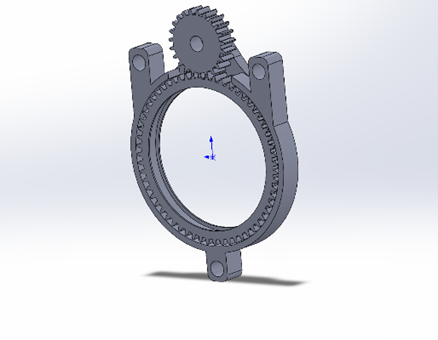
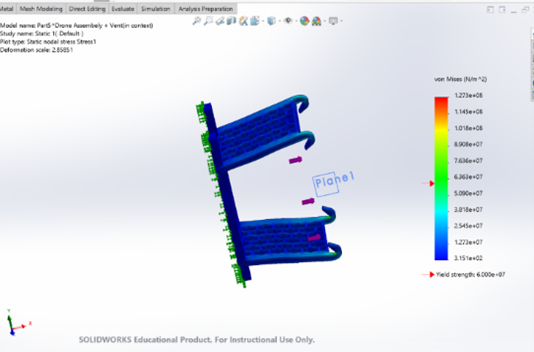
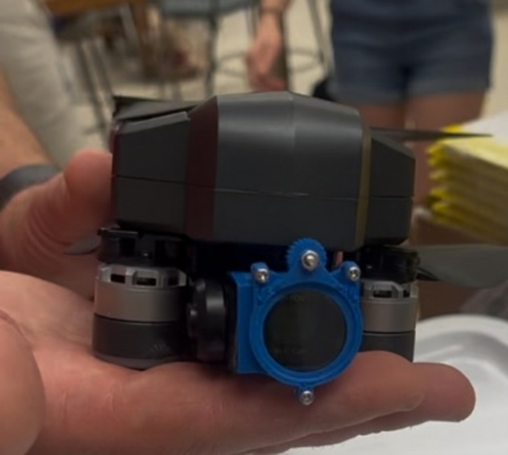
Objective: Design and manufacture a universal filter lens mount for the Roku F1GIM2 UAV that maintains low mass and allows fine angular adjustment.
Methods: Built detailed 3D models in SolidWorks and used static FEA to validate strength of weight-saving pockets and gear teeth.
Results: Produced a compact mount with a gear system that enables precise rotation of multiple filters during flight.
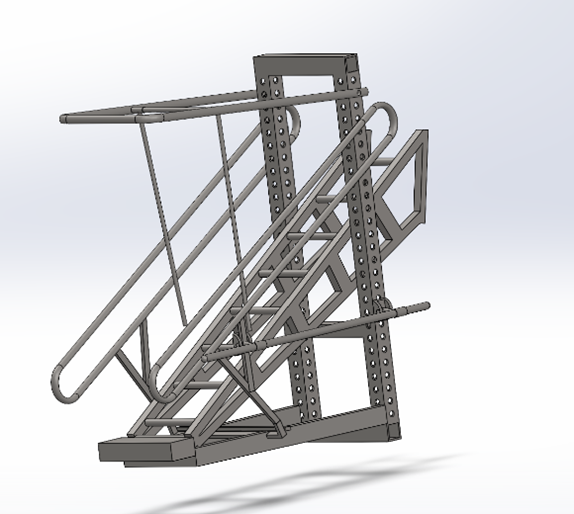
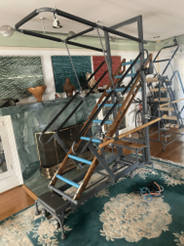
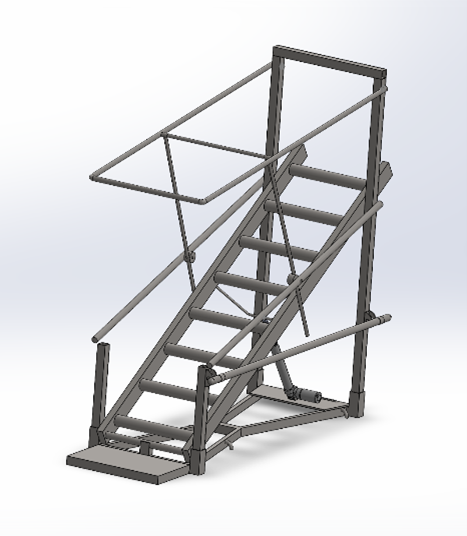
Objective: Develop a full-body stretching machine that can be used for physical therapy and recreational or senior fitness contexts.
Methods: Created a full assembly in SolidWorks and used FEA to compare different chassis geometries while holding aluminum stock constant.
Results: Built and tested two chassis iterations; the second design maintained similar strength with reduced material usage and improved simplicity.
My work focuses on mechanical design, experimental hardware, and aerospace applications where weight, reliability, and manufacturability are tightly constrained.
I enjoy taking designs from CAD and FEA all the way to fabricated hardware: cutting parts on a water jet or mill, welding and assembling, and then learning from how systems perform in real conditions.
I’m especially interested in planetary surface operations, UAV payload integration, and fluid-driven devices for excavation and handling granular materials.
I’m open to internships, research positions, and collaborations related to mechanical and aerospace systems, robotics hardware, and experimental prototyping.